Connecting human intent to intelligent actions.

OpenG2X turns biosignals from
any wearables into commands for
any application.

A person wearing an sEMG wristband offers an egg on an open palm to a robot arm, whose open gripper hovers just above it.

Open input. Open output.

OpenG2X reads muscle (sEMG) and motion (IMU) signals from wearable sensors and recognises the gesture on a pocket-sized edge-AI module. The module then streams the gesture events to any device you choose.

Three sEMG wearables from different makers, a rigid armband, a sleek armband and a textile sleeve, feed the OpenG2X runtime, which sends commands to robots (OpenG2Rob), medical devices (OpenG2Med) or smart glasses (OpenG2Smart). Open input Rigid armband sEMG Sleek armband sEMG Textile sleeve sEMG OpenG2X-compatible sEMG or IMU sensor hardware from any OEM Open output Runtime Robots OpenG2Rob Medical devices OpenG2Med Smart glasses OpenG2Smart Three sEMG wearables from different makers, a rigid armband, a sleek armband and a textile sleeve, feed the OpenG2X runtime, which sends commands to robots (OpenG2Rob), medical devices (OpenG2Med) or smart glasses (OpenG2Smart). Open input OpenG2X-compatible sEMG or IMU sensorhardware from any OEM Rigidarmband sEMG Sleekarmband sEMG Textilesleeve sEMG Runtime Robots OpenG2Rob Medicaldevices OpenG2Med Smartglasses OpenG2Smart Open output
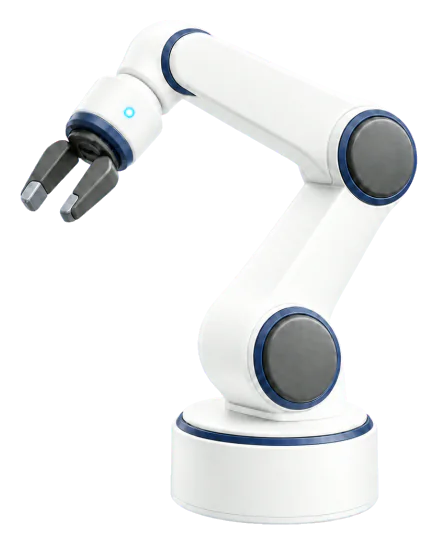
  • A white collaborative robot arm. OpenG2Rob

    Robotics

    Hand over parts and guide cobots by intent. Muscle signals add the grip force that a camera cannot see.

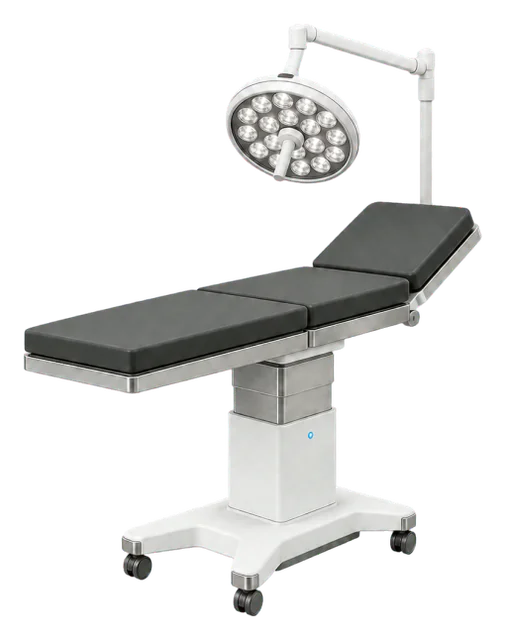
  • An operating table under a surgical light. OpenG2Med

    Medicine

    Touch-free control of imaging and operating tables, without leaving the sterile field.

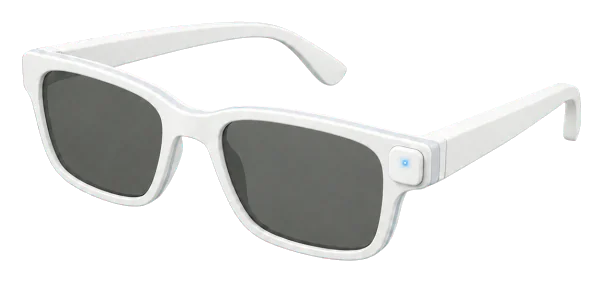
  • White smart glasses. OpenG2Smart

    Smart devices

    Camera-free input for smart glasses and XR headsets that respects the privacy of the people around you.

The team behind OpenG2X

Snaptiq Labs brings OpenG2X to market. The technology builds on our research at Friedrich-Alexander-Universität Erlangen-Nürnberg (FAU) into muscle-signal control and inertial motion tracking.
  • Project lead

    Fabio Egle

  • Tech lead

    Dr.-Ing. Simon Bachhuber

  • Business lead

    Patrick Hinn

  • Advisor

    Prof. Andreas Kist

  • Advisor

    Prof. Claudio Castellini

Partners

  • Assistive Intelligent Robotics
  • anki
  • Friedrich-Alexander-Universität Erlangen-Nürnberg
  • robo.innovate
  • TUM Venture Labs

Funding

EXIST project Naice_Gesture
The programme “exist – from science to business” with its projects is funded by the Federal Ministry for Economic Affairs and Energy and the European Union through the European Social Fund Plus (ESF Plus). Supported by the Federal Ministry for Economic Affairs and Energy on the basis of a decision by the German Bundestag. Co-funded by the European Union. EXIST: from science to business.